
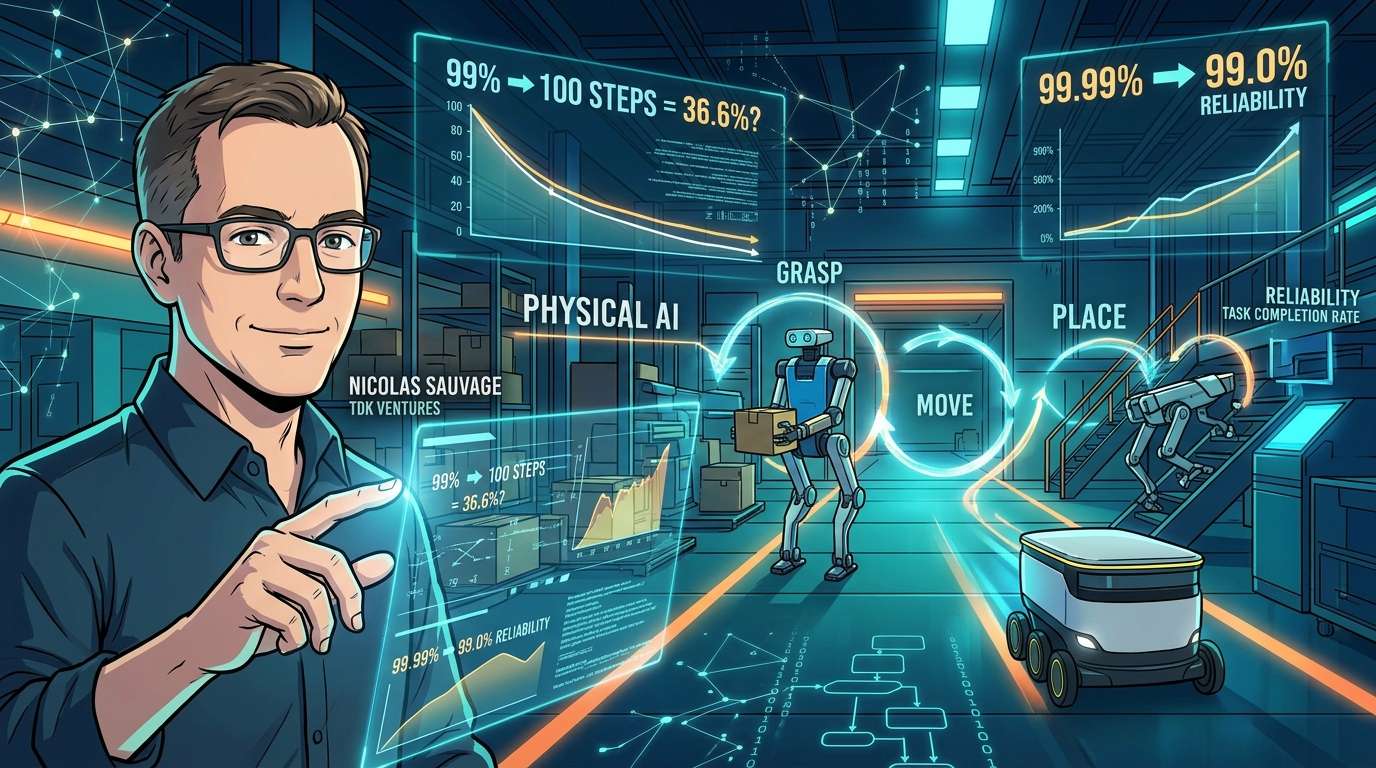
A robot grasps an object, carries it, and sets it down. If each action succeeds 99% of the time, you might think it is close to being practical. But for a job involving 100 consecutive actions, the chance of getting every one right on the first try is only about 36.6%. Nicolas Sauvage, founder and president of TDK Ventures, argues that the challenge of physical AI should be reframed not simply as “dexterity,” but as the reliability to complete an entire process without human assistance.
The pitfall hidden in the 99% figure
Watching a robot demo video, it is easy to think, “It’s already as good as a human.” But the real question is not whether it can succeed once. It is whether it can repeat the task hundreds of times even when an object shifts slightly, the grip changes, parts wear out, or unexpected problems arise.
Sauvage offers a simple, easy-to-understand calculation. For a job involving 100 actions performed in sequence, if each action has a 99% success rate, the chance of getting all of them right on the first try is about 36.6%. At 99.9%, it rises to about 90.5%, and at 99.99%, to about 99.0%. This is an illustrative calculation based on the simplified assumptions that every action has the same success rate and that the actions are independent of one another.
In other words, a robot with a 99% success rate is not 99% automated. The number of 9s, Sauvage suggests, can determine whether a person needs to stand by and supervise or whether the robot can be left to handle the work on its own.
Dexterity lies in the entire process, not just in the hand
A robot’s dexterity is often discussed as a hardware contest over the number of fingers or joints. But customers are not buying degrees of freedom; they are buying useful work, Sauvage points out.
Completing a task requires a continuous closed loop linking vision, positioning, contact, force, pressure, grasping, movement, and adjustment. It must be viewed as a “system” that also includes power, safety, flexibility, and recovery from failure.
Touch can provide useful information—for example, that an object is beginning to slip, contact is unstable, too much force is being applied, or a part has seated correctly. That said, not every task requires tactile sensing; in some cases, visual and motion data are enough. What matters is not adding every possible sensor, but providing enough information for the task at hand.
Robots that can recover from failure are closer to the factory floor
A major part of dexterity is the ability to recover. When an object starts slipping, whether the initial grip was perfect is not the point. The question is whether the robot can detect the slip quickly and correct it before a minor mistake turns into a failure of the entire task.
Failures discovered in the field may stem from software, sensors, or control systems—or they may call for a redesign of the robot itself. Changing the shape of a hand changes its movement, sensor characteristics, and calibration, so data collected for one design cannot necessarily be used as is for another. That is why Sauvage sees field deployment as part of development.
Slips, inadequate grips, wear, and failed recovery all generate data that can feed back into improvements to software, simulation, sensors, control systems, and hardware. The idea is that each time this cycle runs, the next deployment becomes more reliable and less costly. A technical breakthrough is only the starting point; the learning system around it is what multiplies its impact. Sauvage argues that adding more “9s” comes from repeating the cycle of deployment, learning, and improvement.
Choose a form suited to the job, not a humanoid one
The idea that a robot is better the more humanlike it is also needs to be treated with caution. Start with the job, then work backward to determine the environment, form, and systems required. The same logic applies to dexterity: the most humanlike hand is not necessarily the best one. The goal, the author argues, is not maximum dexterity, but “just enough dexterity” to reliably carry out valuable work.
One example is Digit, Agility Robotics’ bipedal robot. Designed for logistics and industry, it can be connected directly to task-specific tools rather than being equipped with a five-fingered hand. The design prioritizes having the form and dexterity the job requires over looking human.
ANYbotics’ quadruped robot inspects hazardous areas while navigating stairs and uneven terrain at industrial facilities, reducing the risk to people. In one reported deployment, it carried out more than 33,000 inspections across 450 inspection points.
Starship Technologies’ delivery robot is designed to travel on sidewalks, making a small wheeled form more suitable than legs. The company reports that this task-specific approach has enabled more than 10 million autonomous deliveries.
The three look completely different, but they share one thing: the right solution is a form suited to the work on site and able to operate repeatedly in that environment. Sauvage says his perspective as an investor has changed through investments in Agility, ANYbotics and Starship. The question is no longer which robot looks most human, but which finished system can deliver the reliability customers demand.
From demo success rates to task completion rates
So how should we measure progress in Physical AI? According to Sauvage, the success rate for a single action in a demo tells us very little about whether a robot can work autonomously in the field.
What matters is the share of processes completed without human assistance. When something goes wrong, how often can the robot recover without help? How does its performance change when objects, lighting, positioning, wear or the surrounding environment change?
There are also less glamorous questions that become more important as operations scale. What breaks first with repeated use? After diagnosis and repair, how quickly can the robot get back to work? How fast can it complete a job successfully, and what are its uptime and cost? These, the argument goes, are better measures of dexterity than a one-off demonstration.
Creating value does not require the most humanlike hand, the most joints or the broadest skill set. What matters is the right combination of physical form, sensing, control and recovery capability, enabling a robot to reliably perform valuable work in the environment where it will actually operate. That, in Sauvage's view, is where the next contest over robot dexterity will be decided.
Comments